Developing the physical platform that carries the vehicle's integrated systems.
MARINE ROBOTICS / ROBOBOAT 2026
DoB Joljan.
An autonomous machine built for the water.
DoB Joljan is an autonomous surface vehicle developed for RoboBoat 2026. I worked as Mechanical Lead, focusing on the physical platform, mechanical development and the integration required to turn multiple subsystems into one working vehicle.
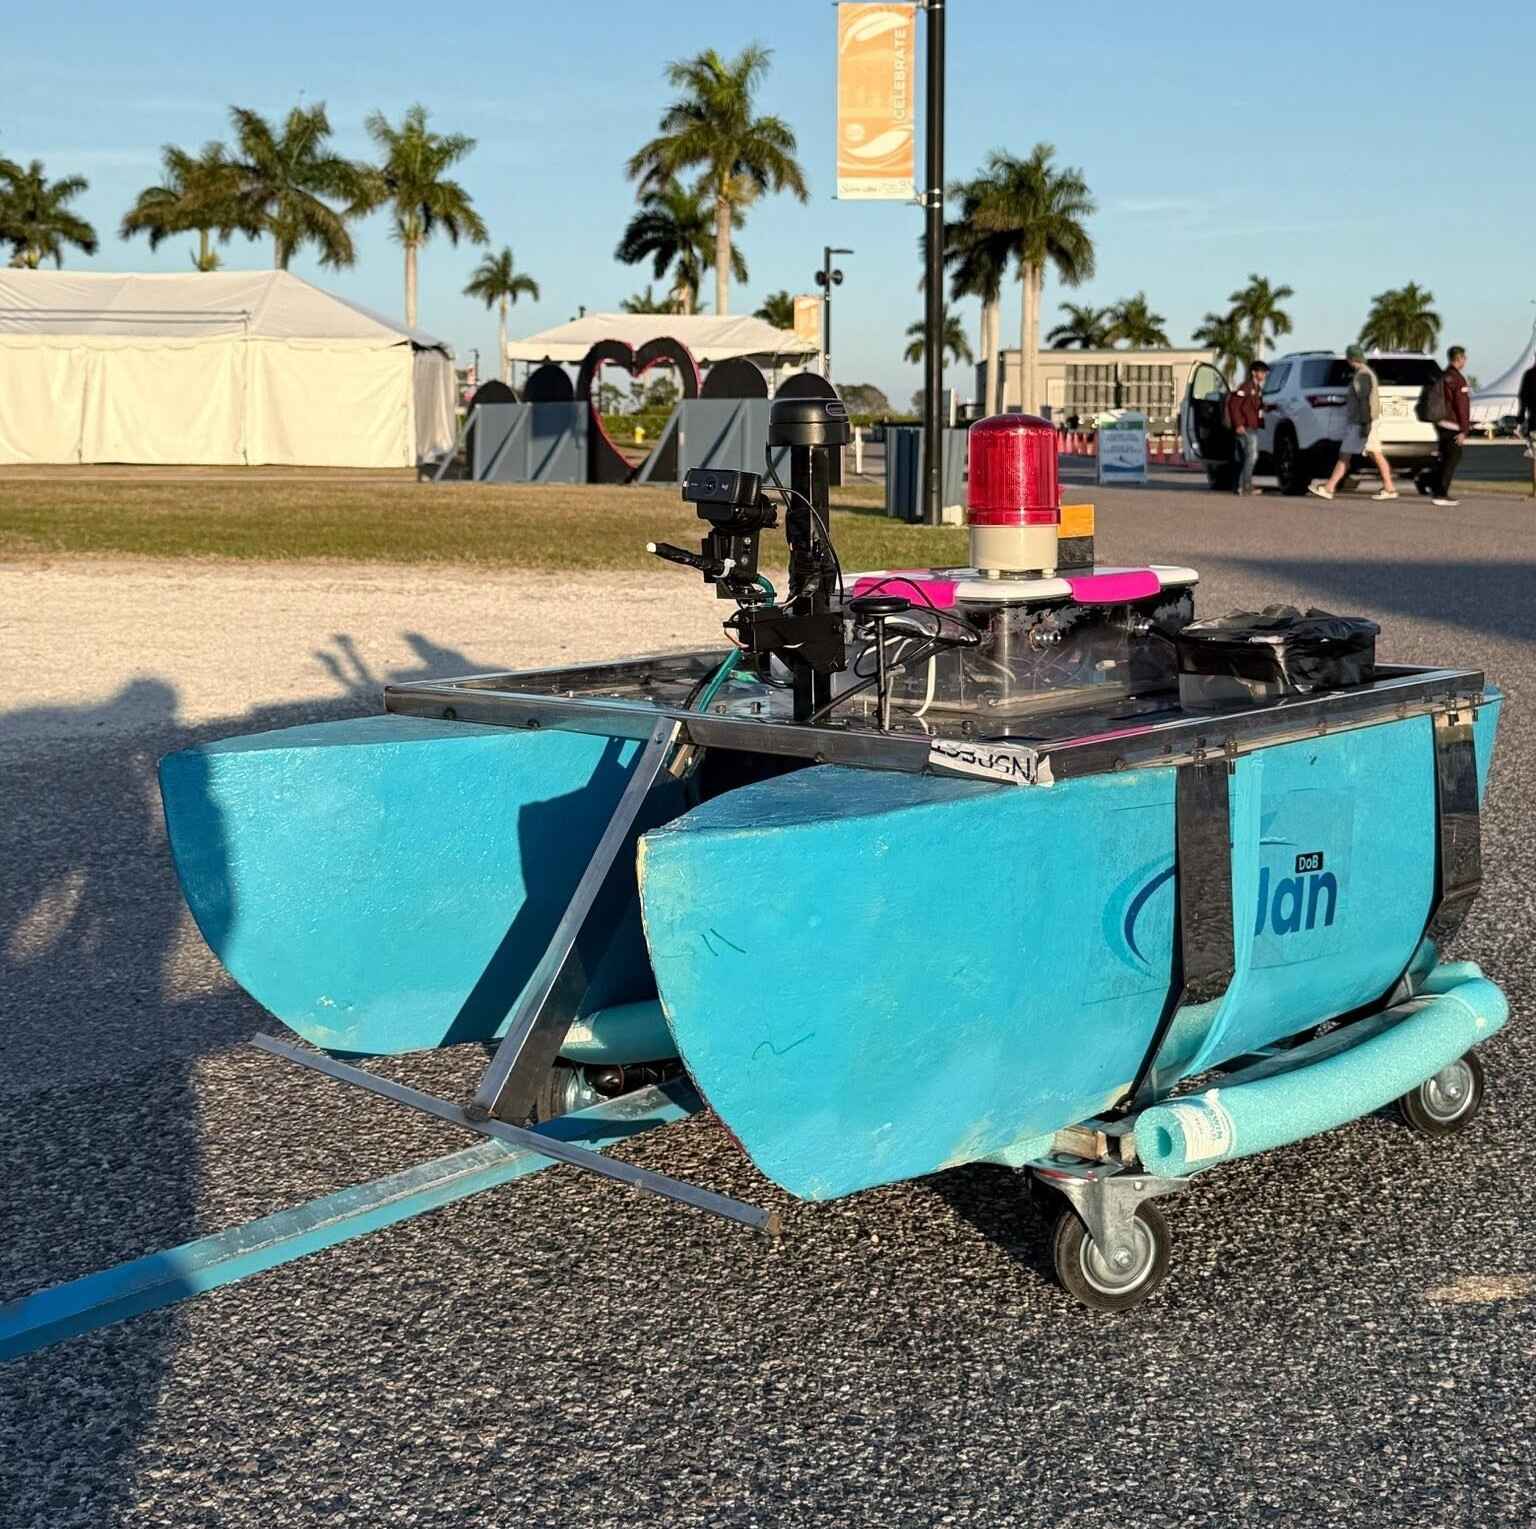 AUTONOMOUS SURFACE VEHICLE
03
THE PLATFORM
One vehicle. Many systems.
MECHANICAL /
INTEGRATION /
MARINE
My responsibility was the machine those systems had to live on.
An autonomous surface vehicle is not simply a collection of electronics placed on a floating structure. Every subsystem needs a physical position, secure mounting, usable access and a structure capable of keeping the complete vehicle together.
As Mechanical Lead, my work centered on developing that physical platform and making the mechanical system compatible with the rest of the vehicle.
Making different components and subsystems physically coexist within one machine.
Providing practical mounting positions and support for hardware across the platform.
Revising the physical build as subsystem requirements and integration problems appeared.
04
MECHANICAL DEVELOPMENT
The hardware has to become one machine.
 MECHANICAL LEAD /
ROBOBOAT 2026
Mechanical integration determines whether the rest of the system can actually operate as a vehicle.
The platform had to accommodate multiple engineering subsystems without treating them as isolated modules.
Changes in one part of the vehicle could affect mounting, available space, access or the arrangement of other components. That made the mechanical work an ongoing process throughout development rather than a chassis designed once at the beginning.
01
Physical platform development and mechanical layout
02
Structural support for integrated vehicle hardware
03
Component positioning and mounting integration
04
Mechanical changes driven by subsystem requirements
05
Iterative assembly of the complete marine platform
05
SYSTEM INTEGRATION
Designed around the whole system.
The mechanical platform had to respond to the requirements of everything built around it.
Autonomous vehicles are inherently multidisciplinary. Mechanical, electrical and computing systems cannot be developed completely independently because each one places physical constraints on the others.
My work involved adapting the mechanical side of DoB Joljan as those requirements developed, keeping the vehicle physically coherent while additional systems were integrated.
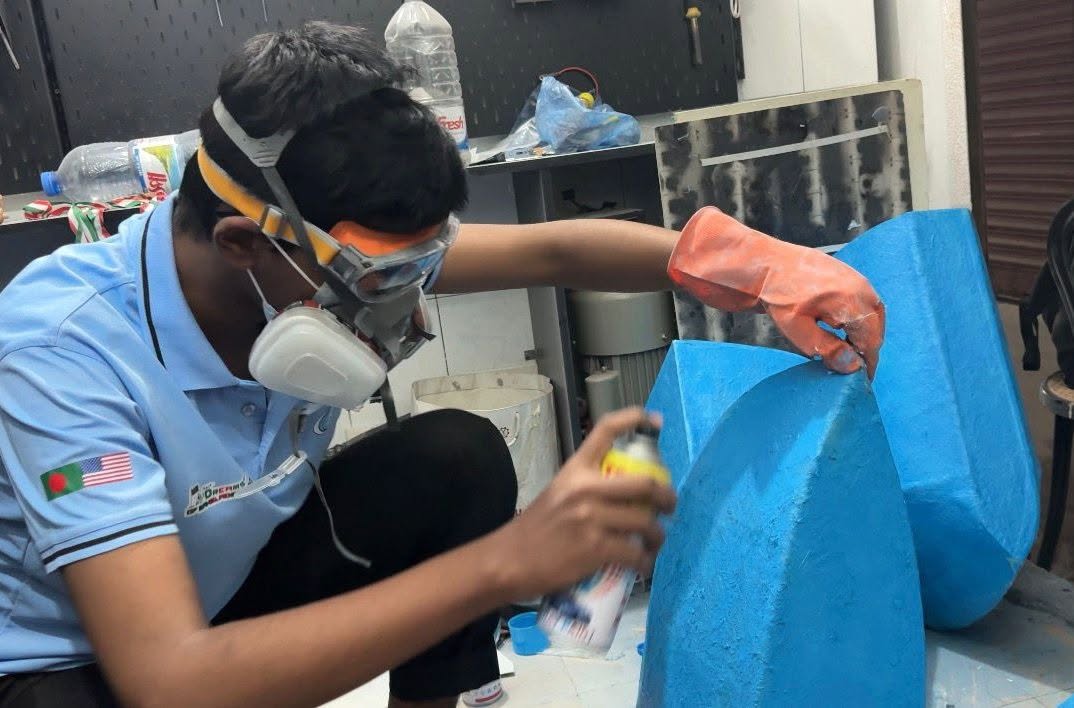 HULL WORK /
BUILD PROCESS
Working directly on the hull during fabrication. Mechanical leadership on the project included both system-level decisions and the physical work required to turn those decisions into a finished platform.
Layout
Components needed positions that made sense not only individually, but as parts of the complete vehicle.
Accessibility
A competition platform must remain practical to assemble, inspect, modify and repair during development.
Integration
Mechanical decisions had to leave room for the other systems required to turn the platform into an autonomous vehicle.
Revision
The physical design changed as new requirements appeared and the integrated vehicle exposed practical problems.
06
MY ROLE
Mechanical Lead meant ownership.
My responsibility was not limited to drawing a mechanical concept.
I worked on the physical development of DoB Joljan and carried responsibility for the mechanical side of the platform as it moved toward a complete autonomous surface vehicle.
That included hands-on fabrication, mechanical assembly, integration work and revising parts of the platform when the larger system demanded it.
DoB Joljan became one of the projects where my role was defined less by a single component and more by ownership of an entire engineering layer of the machine.
PROJECT 04 / 09
PROJECT INDEX